UTT Main Website
UTT Students Design an Underwater Remotely Operated Vehicle
209886 views Print version (opens in a new tab)
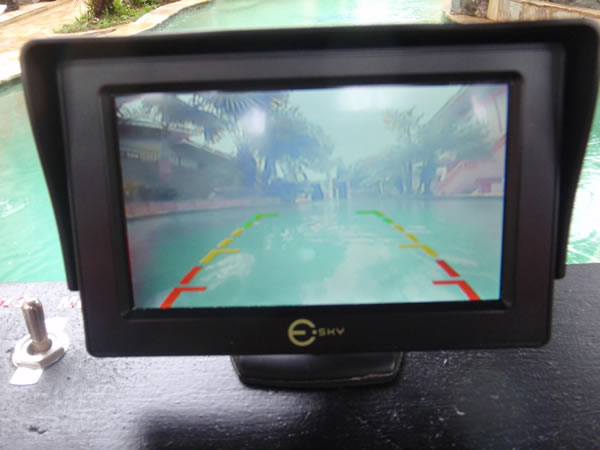
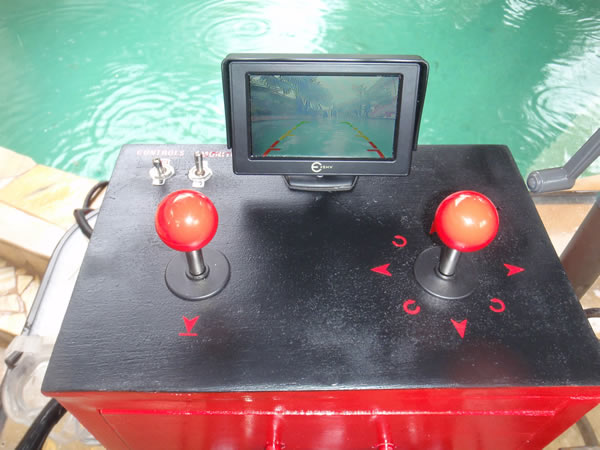
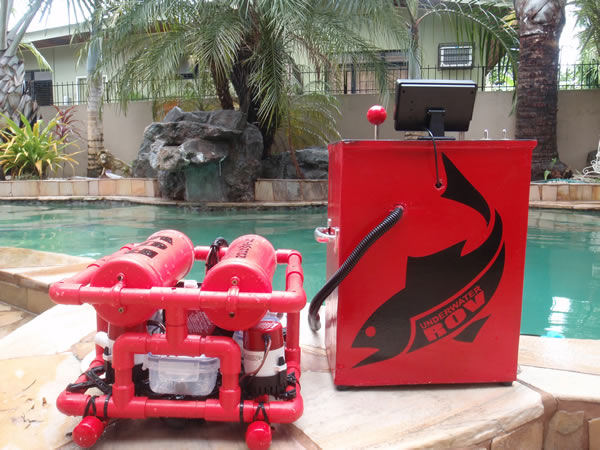
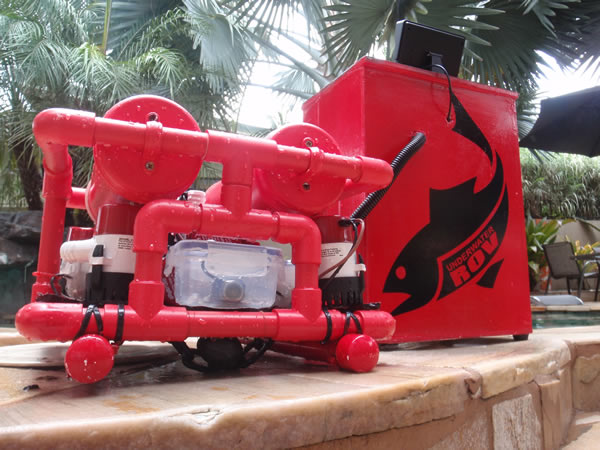
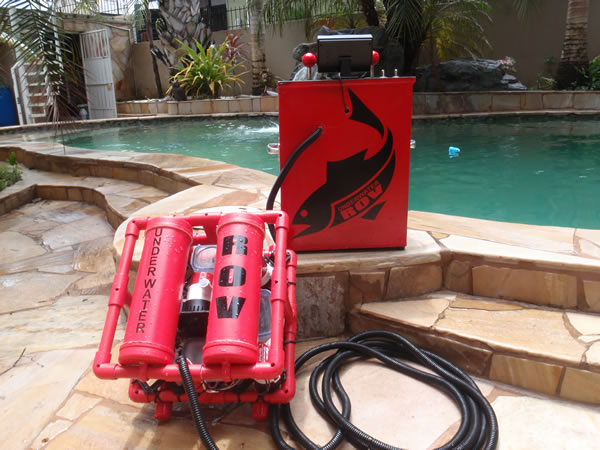
Students in the NETD in Electrical / Electronic Engineering at John Donaldson campus built the ROV using PVC for the frame and ballast containers and a car battery to power the vehicle. The cameras and electronics were placed in air tight food containers and they used a video game controller to control the six (6) bilge pumps that control the movement of the ROV.
 |
 |
 |
 |
 |
|
An Underwater Remotely Operated Vehicle (ROV) - by Thorne Soudama, Michael Lagan and Adryan Dowden